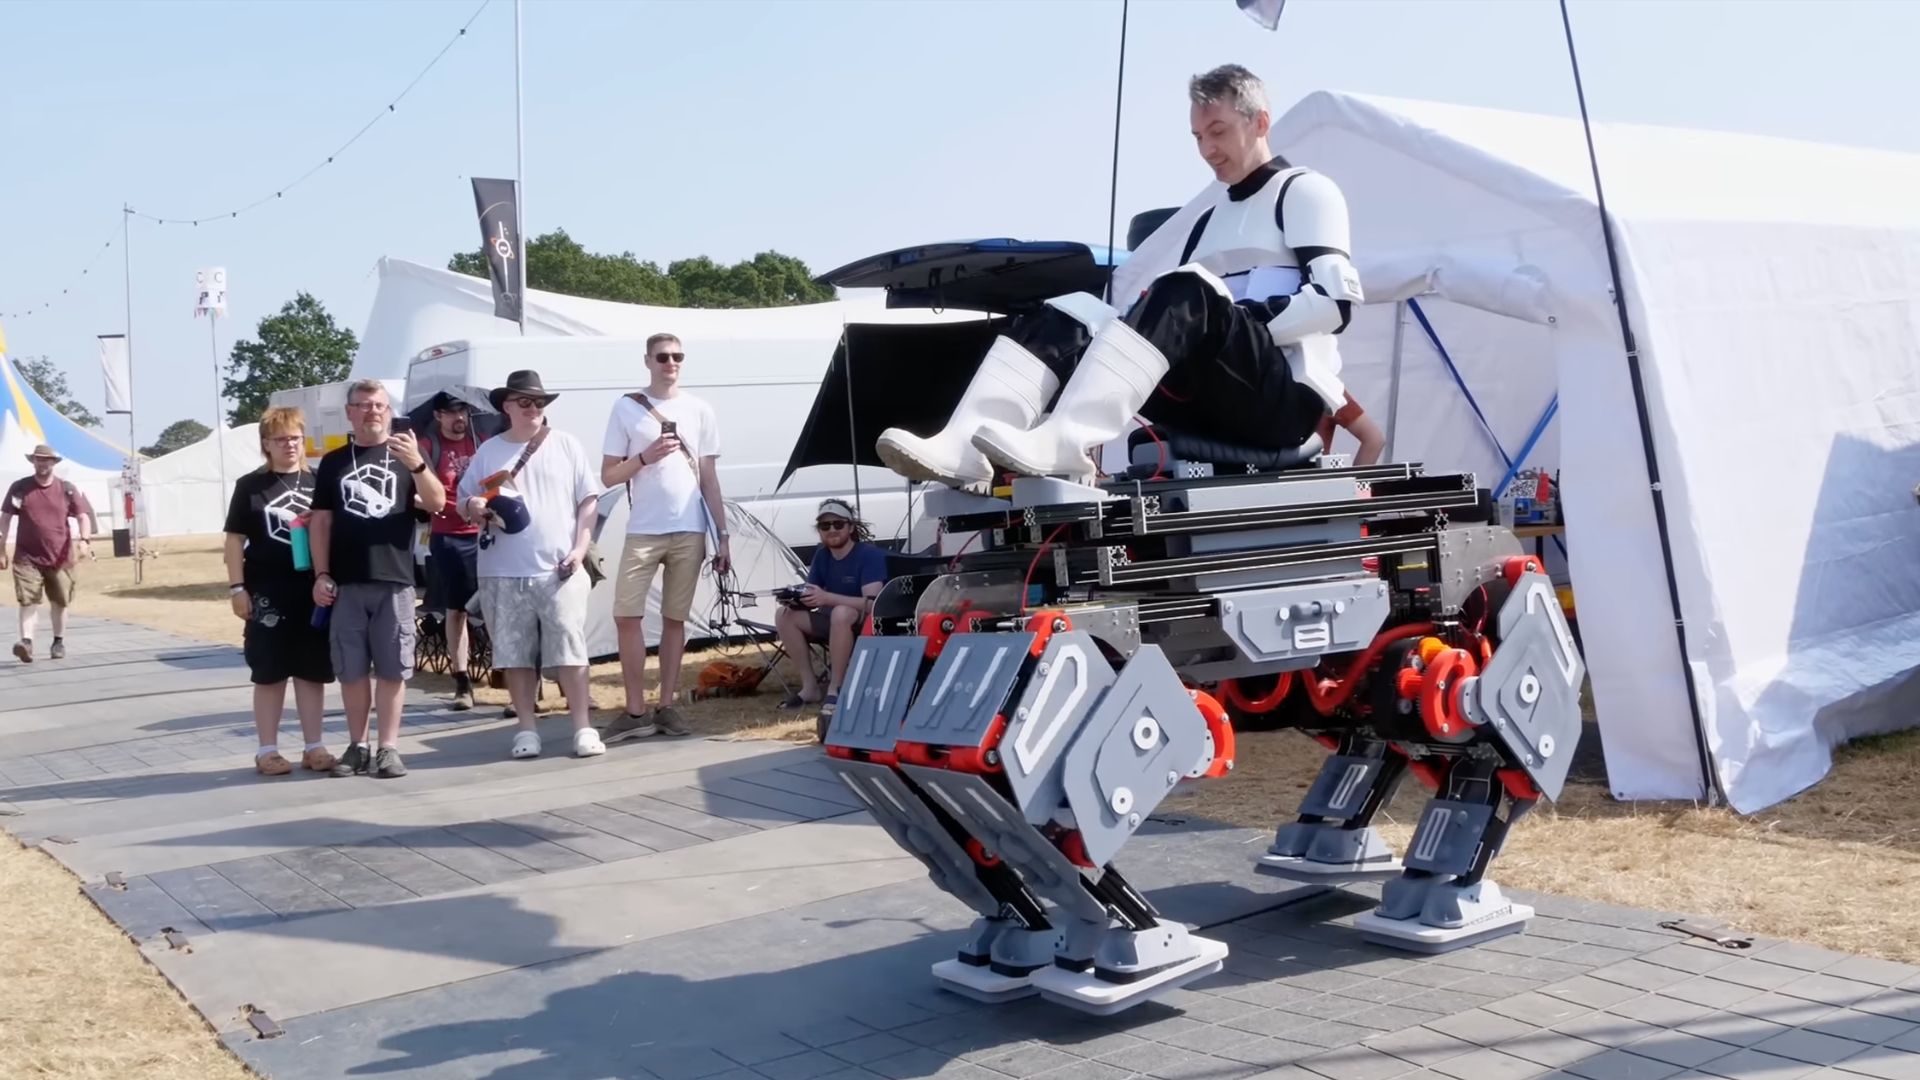
James Bruton's Mid-Walker quadruped robot is an impressive feat of engineering, but its journey to becoming a fully functional, human-carrying machine has been a bumpy one. The latest iteration, showcased at Electromagnetic Field Camp, highlights a critical design flaw: the robot's inability to navigate uneven terrain gracefully. This issue stems from the robot's feet, which struggle to maintain stability on soft grass or dips, causing it to tip over. Bruton's innovative approach to solving this problem involves a combination of everyday objects and advanced materials, showcasing his ingenuity and resourcefulness.
The Mid-Walker's unique design, with diagonally connected legs, ensures stability on flat surfaces. However, when the ground becomes uneven, the robot's weight distribution becomes a challenge. Bruton's solution involves a sliding seat mechanism, which helps the robot adjust to changes in terrain. This mechanism, powered by a 2-kilowatt motor, moves the seat from side to side, allowing the rider's weight to shift and improve balance. While this feature is a step in the right direction, it's not enough to overcome the robot's vulnerability to soft grass and uneven terrain.
The robot's earlier feet, made of hard materials with simple wedge-shaped plywood soles, were designed to reduce the electrical load on the motors. However, these rigid soles failed to provide the necessary grip on uneven ground, leading to instability. Bruton's next innovation draws inspiration from bean bags. He replaced the rigid soles with fabric coverings filled with dried beans and 3D-printed 20-sided dice. This design aimed to mimic the behavior of a bean bag, allowing the feet to change shape and become firm under the robot's weight. However, field testing revealed that overfilling the feet made the problem worse, and a more durable cloth construction was eventually adopted.
The key to success lies in finding the right balance between flexibility and stability. Bruton's experiments with different fillings and materials showed that the feet needed to move enough to conform to the ground while remaining stable under heavy loads. He is now exploring the use of smaller particles, such as BB pellets, and vacuum systems to improve the locking effect. However, he favors a simpler approach, incorporating passive two-way pivot ankles that can self-level and lock in place using bar clamps. This design aims to detect firm contact and trigger the clamps without adding another motor to the walking system.
Bruton's journey with the Mid-Walker is a testament to the challenges of robotics engineering. His willingness to experiment with unconventional materials and designs showcases his dedication to pushing the boundaries of what's possible. While the robot still has a way to go before it can navigate any terrain with ease, Bruton's continuous innovations bring it one step closer to becoming a practical, human-carrying machine.